
Srikanth Thirumalai, Waymo’s vice president of onboard software, argues that true autonomy requires a redundant architecture. By combining cameras with lidar and radar, Waymo creates a multi-layered perception of the world that single-sensor systems struggle to replicate. This stance directly challenges Musk, who has long dismissed lidar as a costly crutch, famously predicting that competitors relying on the technology are doomed to fail.
Waymo Challenges Tesla’s Camera-Only Autonomous Strategy
As Tesla prepares to debut its steering-wheel-free Cybercab, Waymo has launched a direct critique of the camera-only vision approach favored by Elon Musk. In a technical summary of its own 200 million miles of autonomous driving, the Alphabet-owned company insists that visual sensors alone cannot guarantee safety at scale.
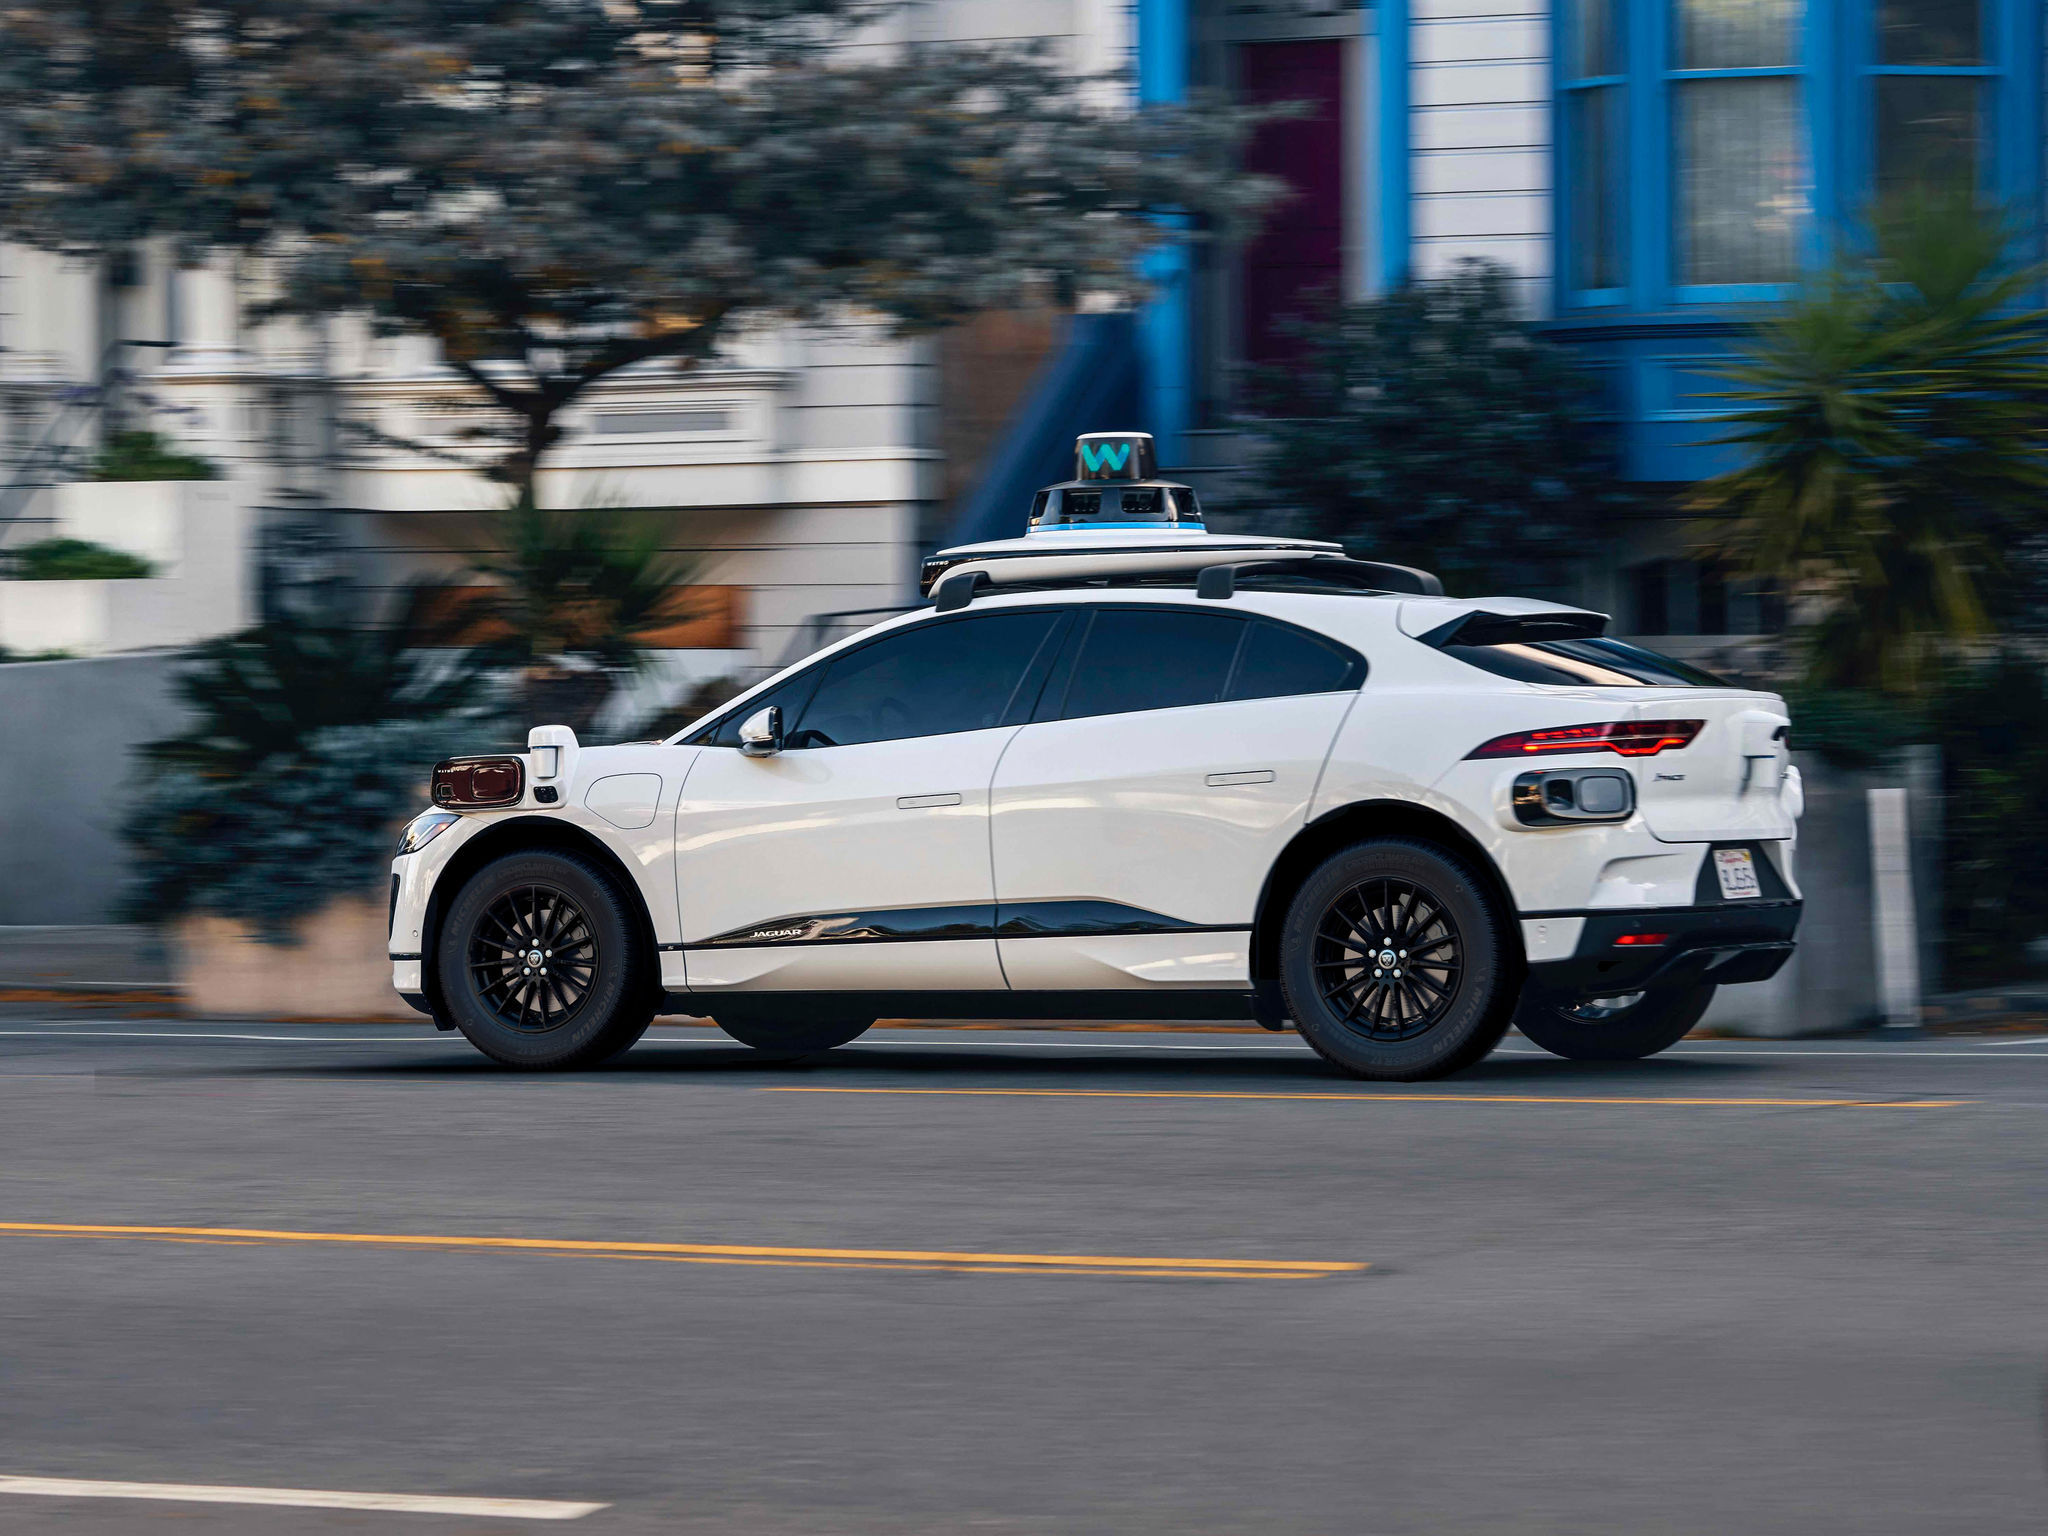
Tesla remains unmoved by this criticism. During a recent earnings call, Ashok Elluswamy, the company’s head of AI, doubled down on the camera-first philosophy, dismissing the multi-sensor approach as unnecessary. The disagreement highlights a fundamental divide in the industry: whether machines should mimic human biological sight or utilize diverse sensor suites to achieve a more reliable safety threshold in complex urban environments.

Comments (0)
No comments yet. Be the first!